News
October 01, 2026
 'NanoCockpit: Performance-optimized Application Framework for AI-based Autonomous Nanorobotics', from IDSIA USI-SUPSI, published in IEEE Robotics and Automation Practice, was presented at IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026 in Pittsburgh, USA
September 01, 2026
 'NOVA: Neuromorphic Optical Flow for Event-Based Visual Odometry', from University of Bologna, has been accepted to the 'Workshop on Neuromorphic Vision' (NeVi), held in conjunction with the European Conference on Computer Vision (ECCV 2026), in Malmö, Sweden
June 30, 2026
 'Thinking Fast, Thinking Slow: Adaptive Multimodal Transformer-based Sensor Fusion for Depth Estimation on Ultra-low-power MCUs', from IDSIA, SUPSI, has been accepted for publication to IEEE Sensors Journal
June 15, 2026
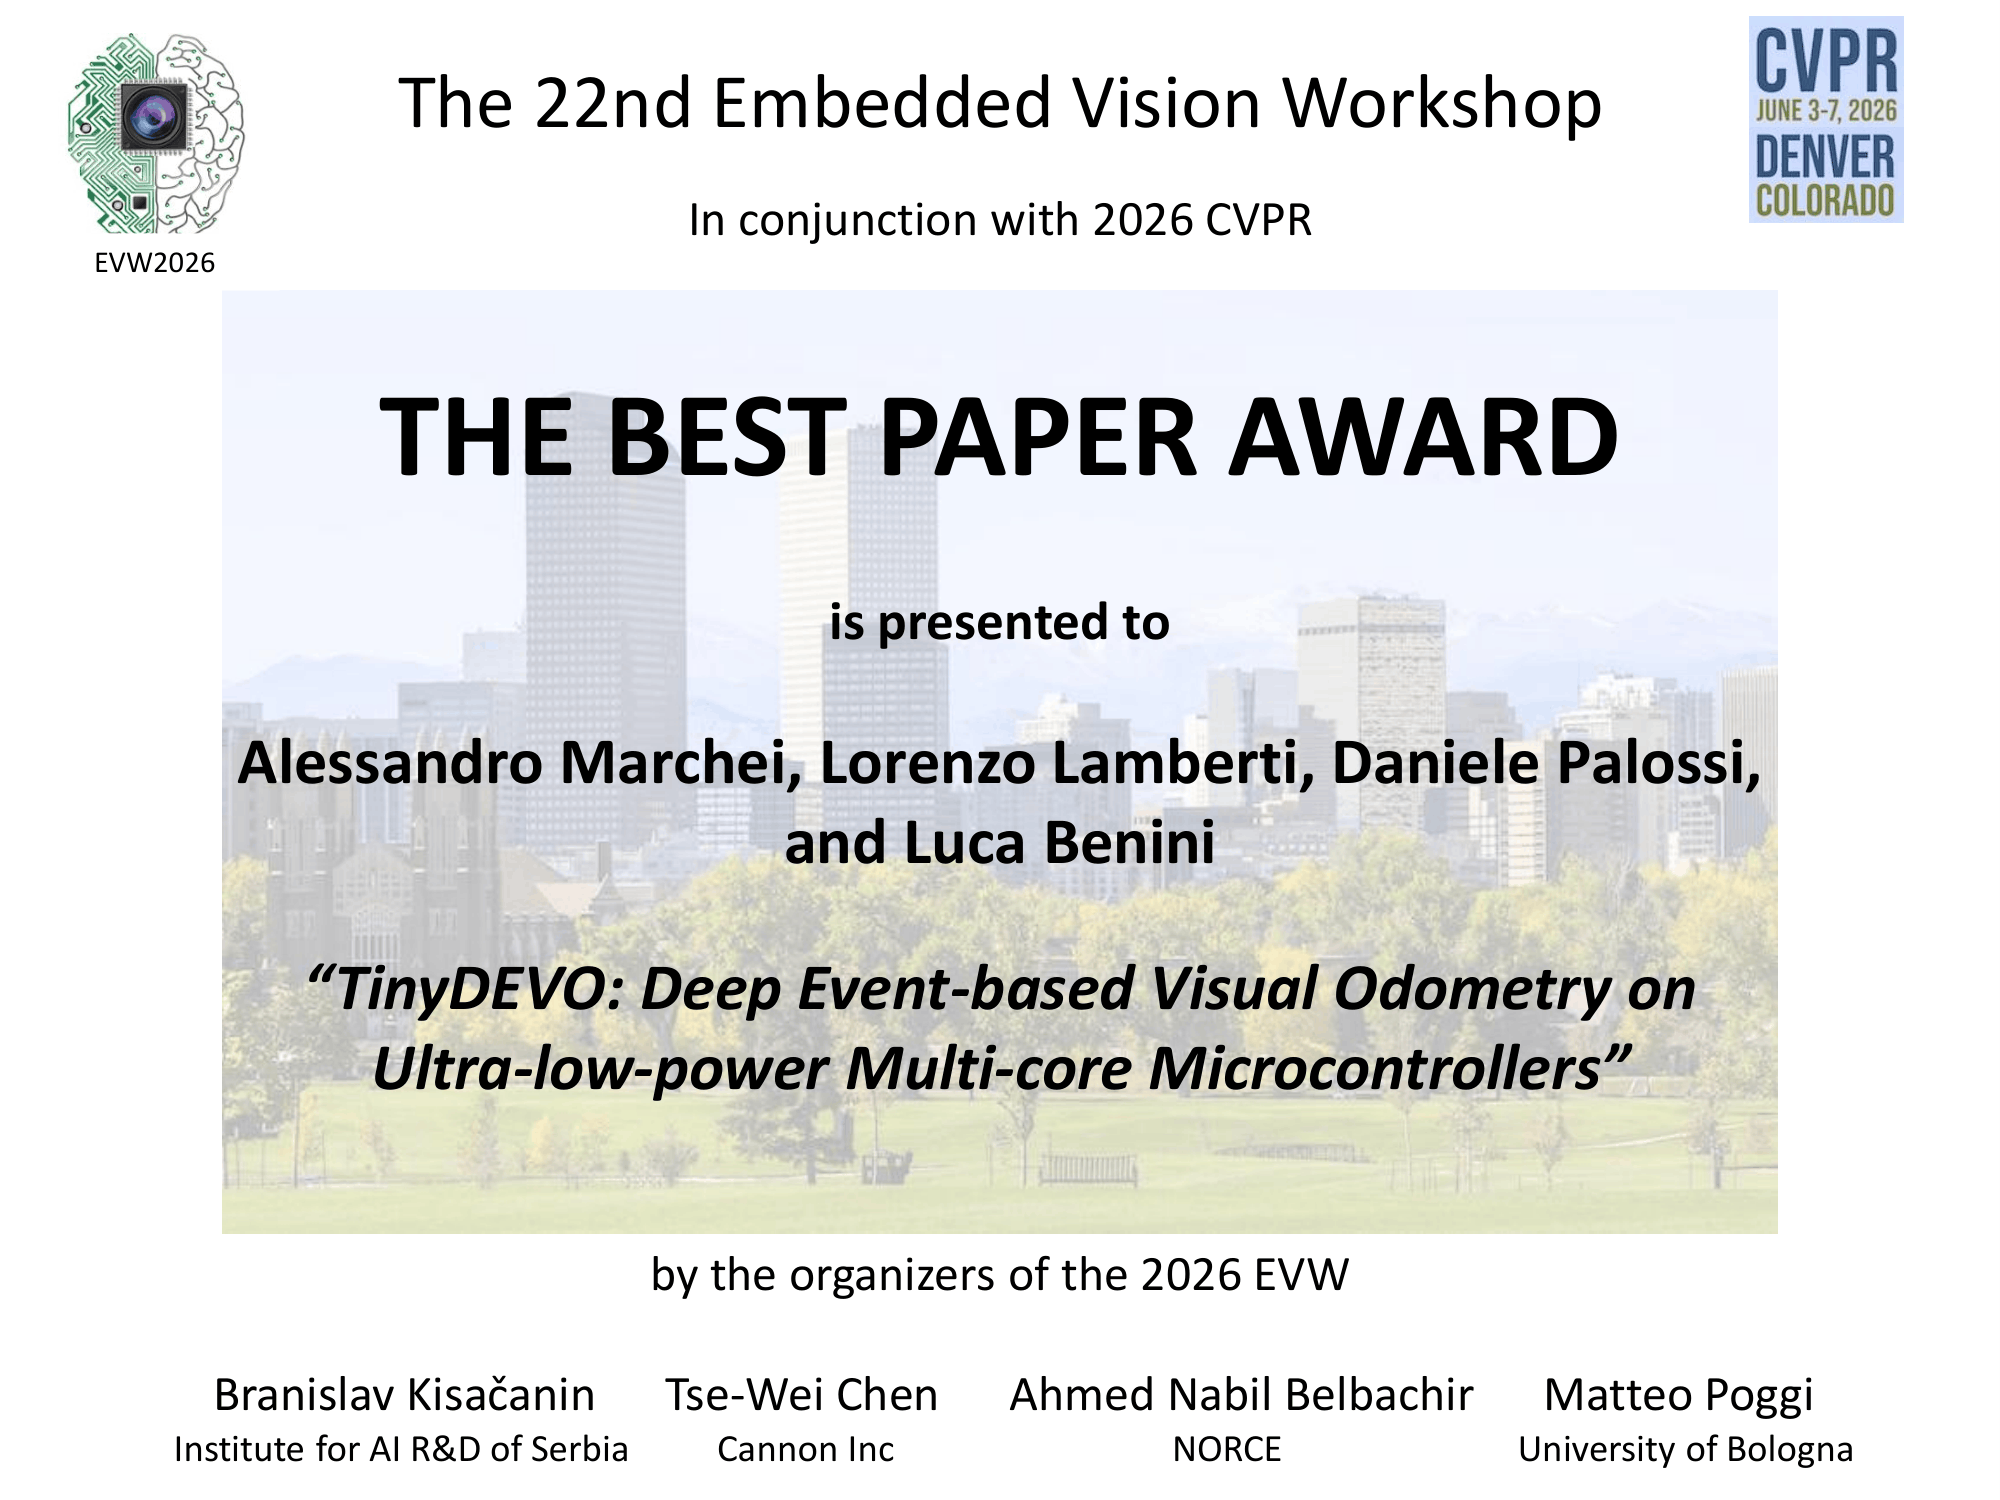 'TinyDEVO: Deep Event-based Visual Odometry on Ultra-low-power Multi-core Microcontrollers' received the Best Paper Award at the Embedded Vision Workshop (EVW), in conjunction with CVPR 2026!
April 10, 2026
 'TinyDEVO: Deep Event-based Visual Odometry on Ultra-low-power Multi-core Microcontrollers', from ETH Zurich, has been accepted to the Embedded Vision Workshop, held in conjunction with IEEE/CVF Conference on Computer Vision and Pattern Recognition 2026 (CVPR 2026)
January 31, 2026
 'Tiny-DroNeRF: Tiny Neural Radiance Fields aboard Federated Learning-enabled Nano-drones', collaboration between IDSIA USI-SUPSI, University of Bologna and ETH Zurich, has been accepted to ICRA 2026
December 01, 2025
'Multi-modal On-Device Learning for Monocular Depth Estimation on Ultra-low-power MCUs', collaboration between IDSIA USI-SUPSI, UNIBO, KU Leuven and ETHZ, has been accepted for publication in the IEEE Internet of Things Journal
'Multi-modal On-Device Learning for Monocular Depth Estimation on Ultra-low-power MCUs', collaboration between IDSIA USI-SUPSI, UNIBO, KU Leuven and ETHZ, has been accepted for publication in the IEEE Internet of Things Journal